DARDAN Alpha
Current focus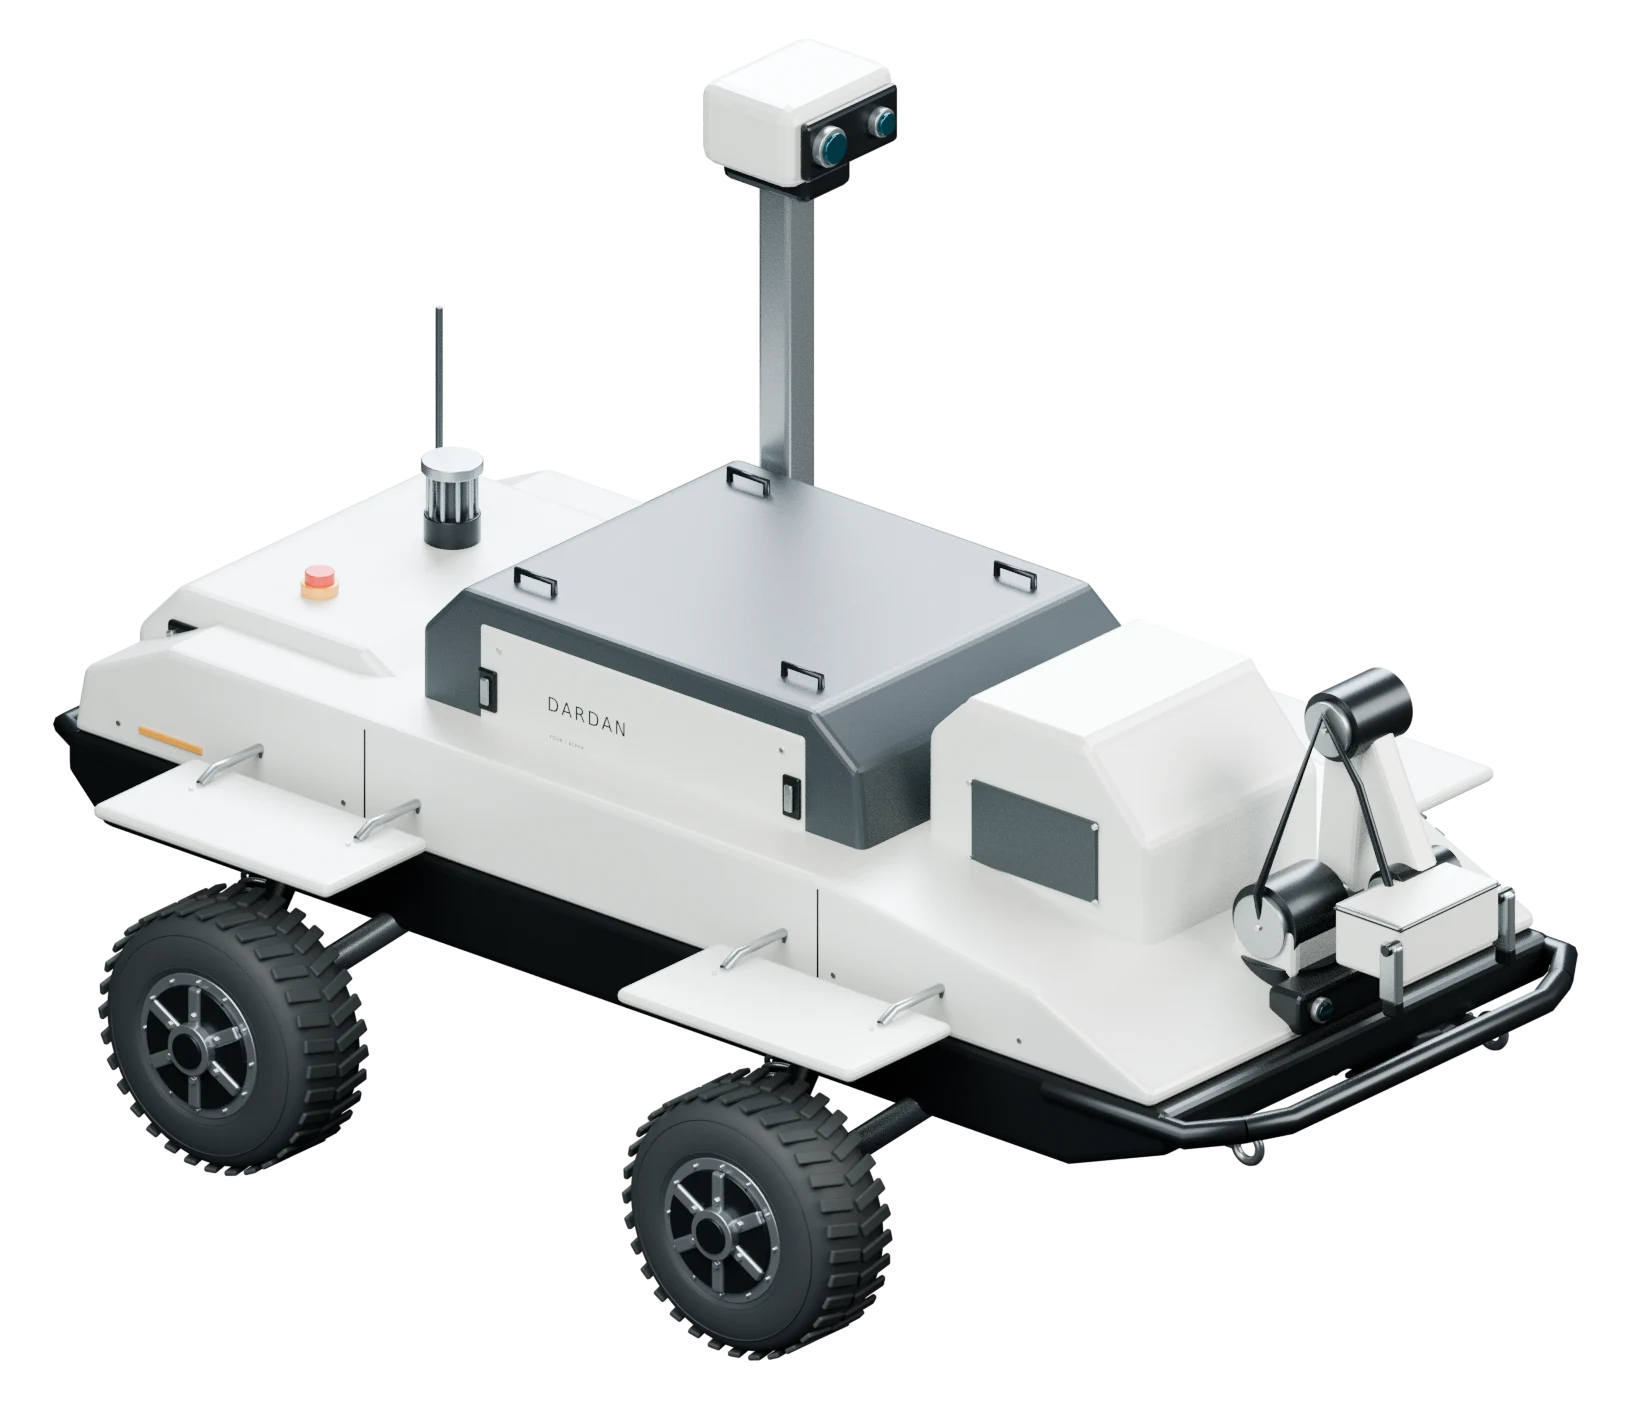
Four wheels · Concept design
Explore Alpha in 360°
Project DARDAN Industrial robotics
DARDAN is developing intelligent robots for industrial inspection, starting with methane inspection for oil and gas operators in Texas.
Explore the conceptsDARDAN Alpha / Concept designThe concepts
Alpha is our current development focus.
Four wheels · Concept design
Explore Alpha in 360°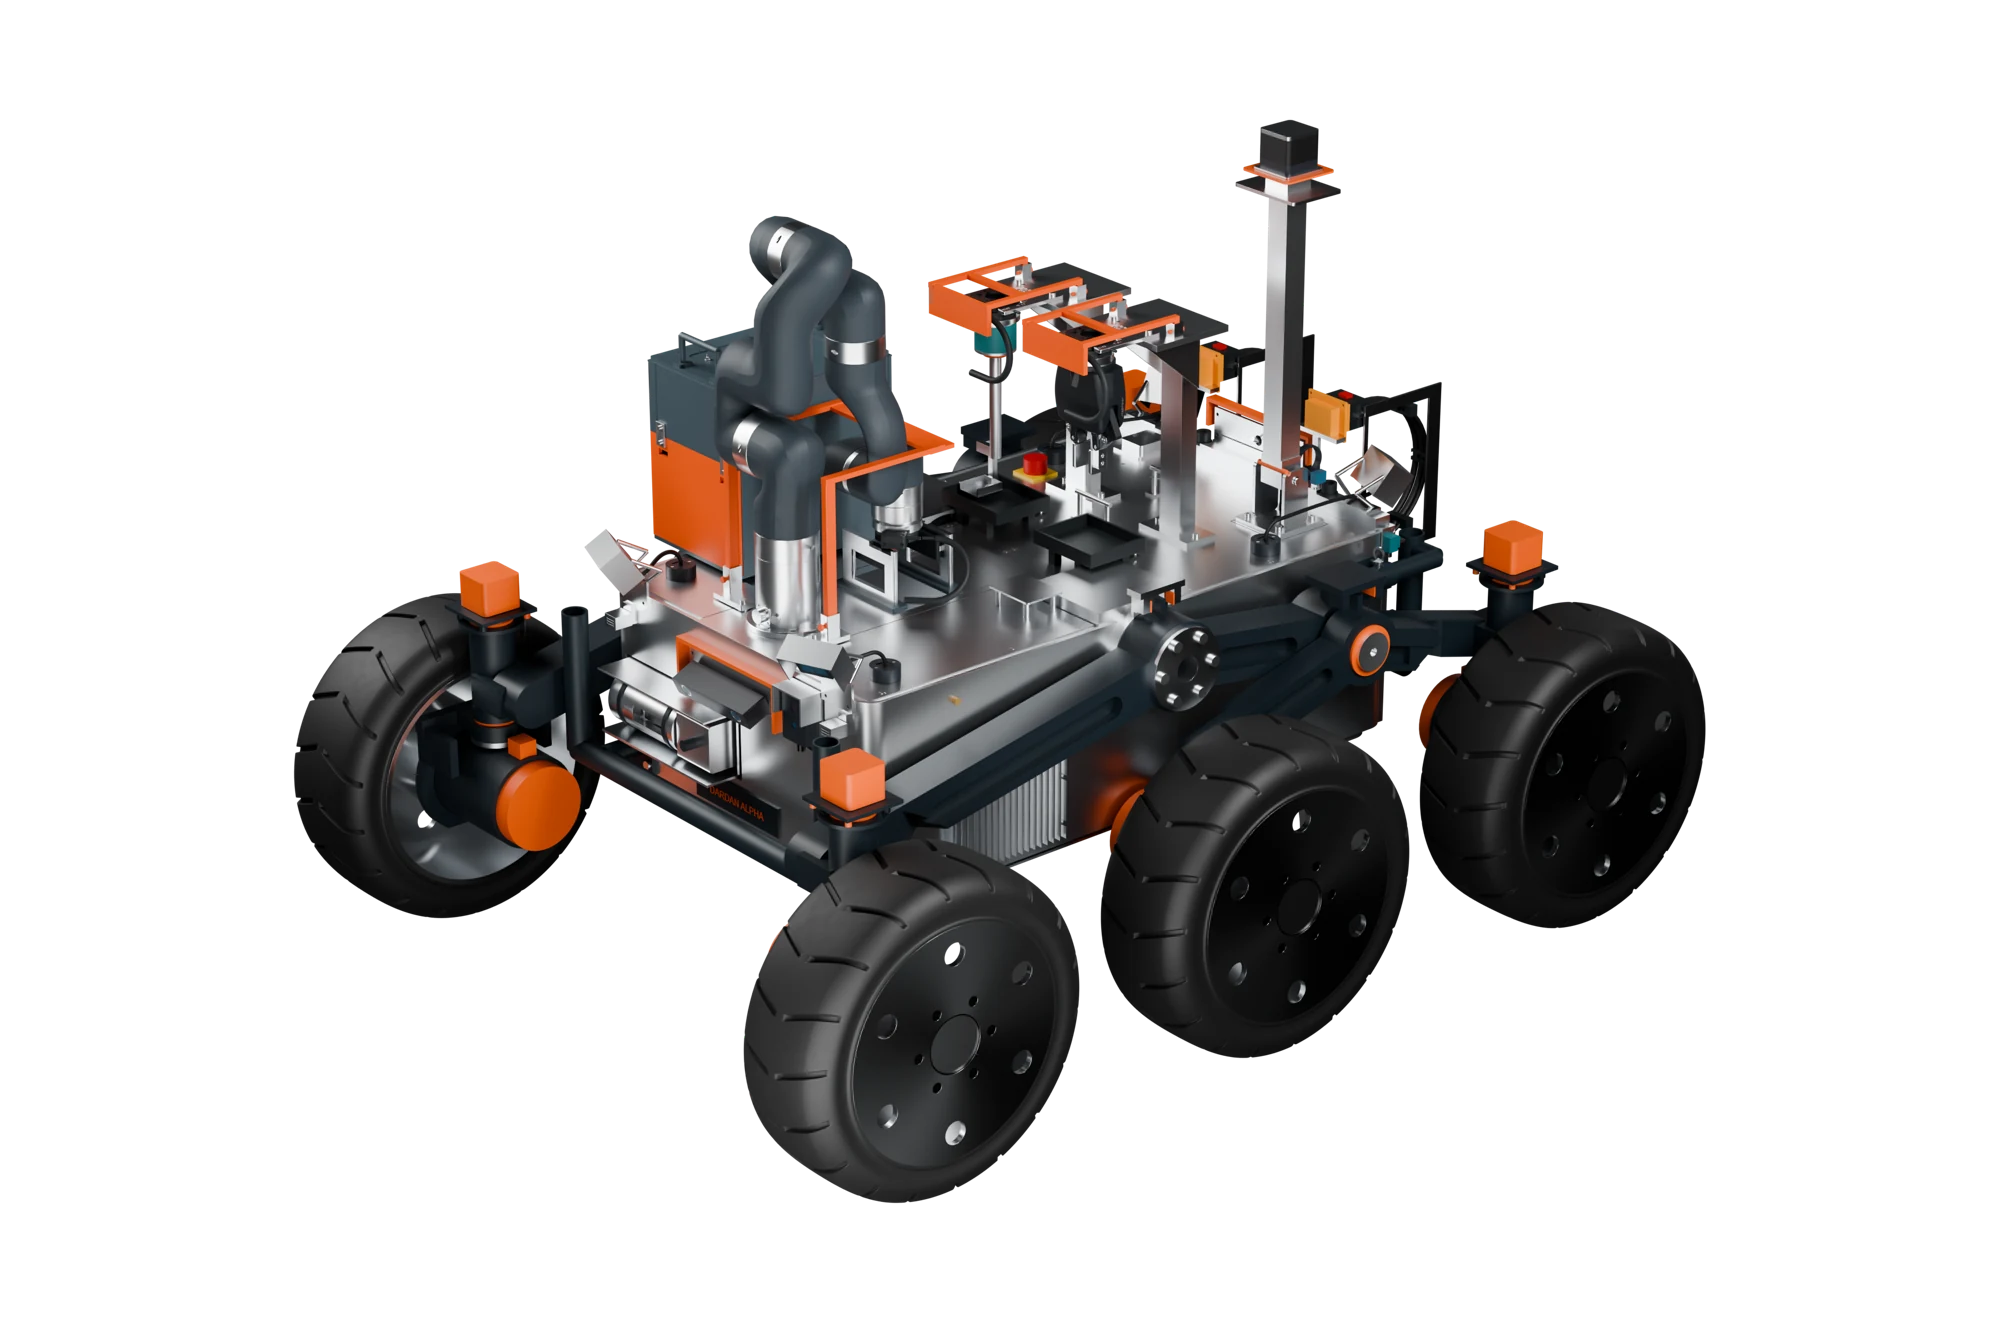
Six wheels · Concept design
Explore Beta in 360°The platform
The ALPHA concept brings mobility, inspection sensing and modular tooling onto one serviceable platform. Explore the proposed architecture.
Four-wheel architecture / Concept design
Inspection sensing
The sensing architecture is intended to pair methane measurements with visual, thermal and location data so each finding can be reviewed in its site context.
Development focus: sensor selection, integration and calibration.
Intelligent industrial robotics
We are building a robotics company around the complete machine: mobility, sensing, onboard intelligence and serviceable hardware. Alpha is our first development platform, with a product strategy that connects robot design and manufacturing to software and field support.
The autonomy program is intended to bring more of the inspection work onto the robot: interpreting findings, carrying out bounded rechecks and preparing records for operator review, including when connectivity is limited.
Company overview for investorsIntended applications
Our initial focus is methane inspection for Texas oil and gas operators: repeatable routes, traceable measurements and less human exposure to demanding field conditions.
Planned inspection routes around valves, pipework and process equipment, combining methane sensing with a visual record for an operator to review. Initial field work would use a verified non-hazardous route.
First application focus
Heat, dust, uneven ground and long travel distances shape the thermal, mobility and serviceability programme. These conditions must be tested together on the complete machine.
Environmental qualification target
The arm, tool interfaces and sample cassette form part of the proposed architecture. Physical handling, containment and operator procedures remain part of the validation work.
Additional development workstream
Every angle matters
DARDAN Alpha & DARDAN Beta.
Concept designs.
Drag to rotate. Scroll or pinch to zoom. Arrow keys rotate; + / − zoom; Home resets.
Load the 360° view to explore the four-wheel model.
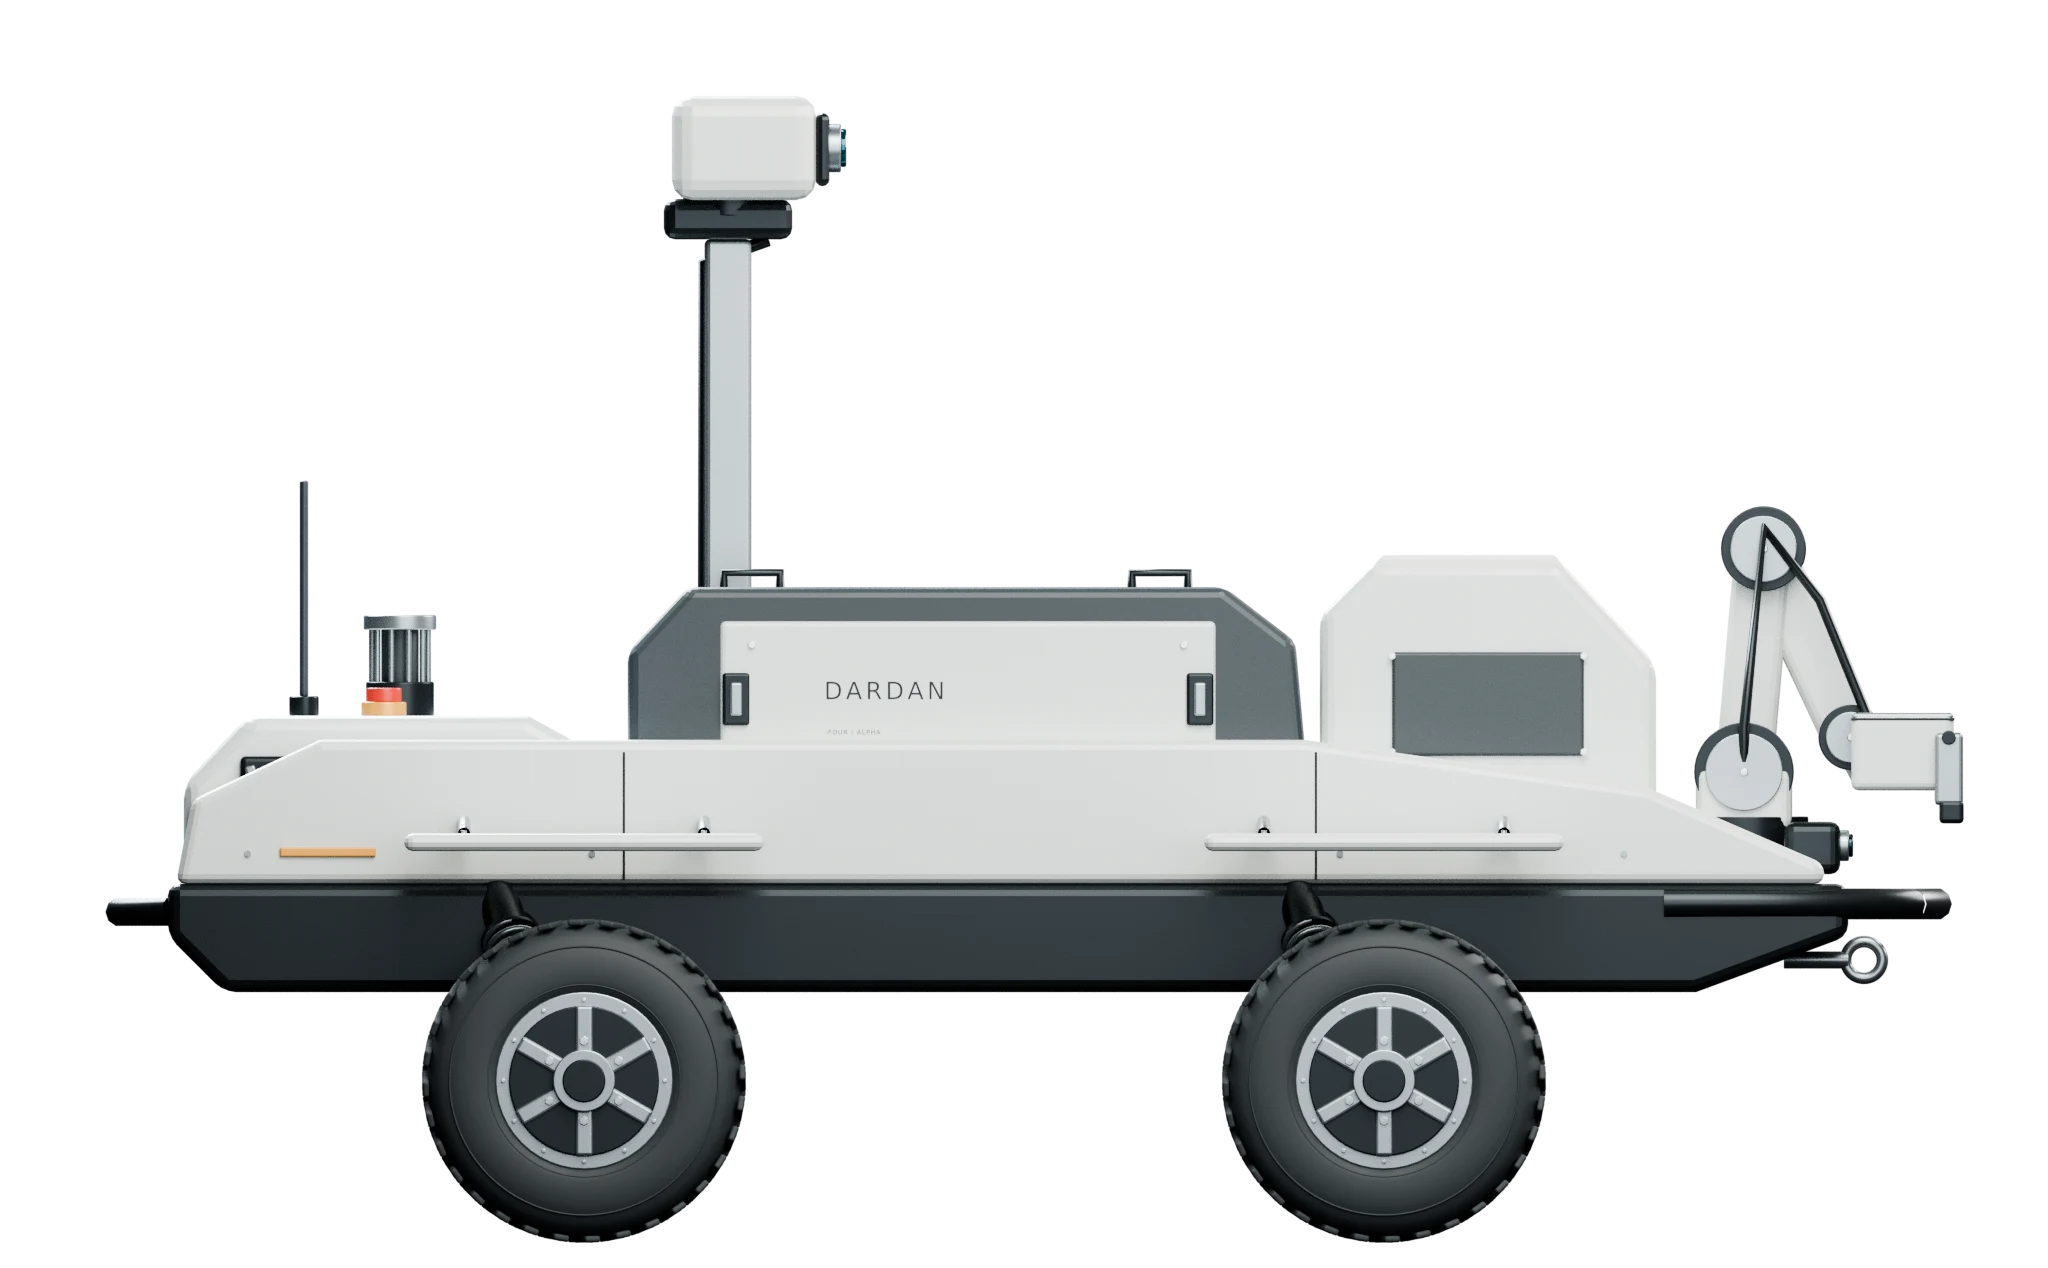
DARDAN Alpha · Four-wheel concept design.
Development programme
Progress depends on what the complete system can demonstrate. The programme follows a staged path from engineering definition to a site-specific pilot.
Current foundation
System architecture, engineering documentation and the current visual concept establish the development baseline.
Next development stage
Supplier confirmation, prototype assembly and integration of sensing, power, mobility and controls.
Validation ahead
Thermal behaviour, safe motion, dust exposure, mobility and mission endurance require physical evidence.
Proposed field stage
Agree a site, inspection scope and acceptance criteria with an operating partner before field evaluation.
We are seeking a Texas operating partner for a supervised methane-inspection pilot, following prototype integration and controlled testing. No pilot site or operating partner is secured. The proposed evaluation would measure how well the rover records methane readings, maps findings and supports repeatable inspection routes, beginning on a verified non-hazardous route.
Discuss a pilot requirementBehind the programme
Founder, Project DARDAN
Senton leads DARDAN’s commercial strategy, partnerships and team development, with a focus on building robotics that protect people in hazardous industrial environments. His background spans telecom market entry, international partnerships and advisory work.
Explore technical collaborationStart a conversation
For pilot interest, engineering collaboration
or an investor brief, contact Senton.